UNDERGRADUATE RESEARCHER IN AUTOMATION, ROBOTICS & AEROSPACE PROPULSION | FOUNDER @ ROCKETRY & RESEARCH CLUB
I am a mechatronics and robotics engineer specializing in hybrid control systems, deterministic real-time architectures, and high-fidelity aerospace propulsion simulations. With a strong foundation in bridging physical hardware with numerical analysis, I design and construct solid rocket motor ballistics platforms and deploy vision-guided autonomous navigation pipelines. My expertise extends to programmable logic controllers (PLCs), multi-modal sensor fusion network design, and non-linear finite element structural stress modeling.
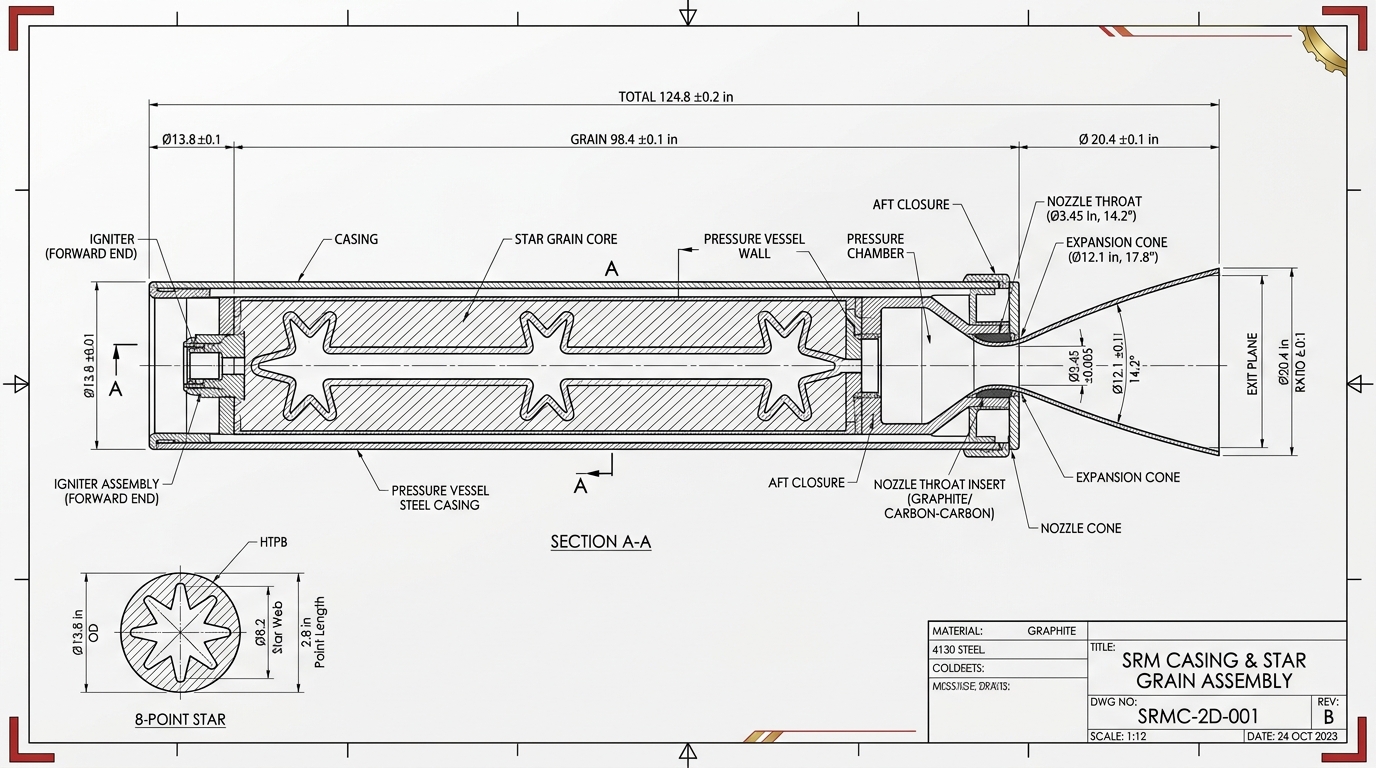
Optimized a solid rocket motor propellant grain using MATLAB simulations and finite element stress verification. Designed an 8-point star grain geometry to control chamber regression rates and prevent pressure spikes. High-pressure static test firings validated a peak thrust of 12.4 kN, matching mathematical models with under 2.8% deviation.
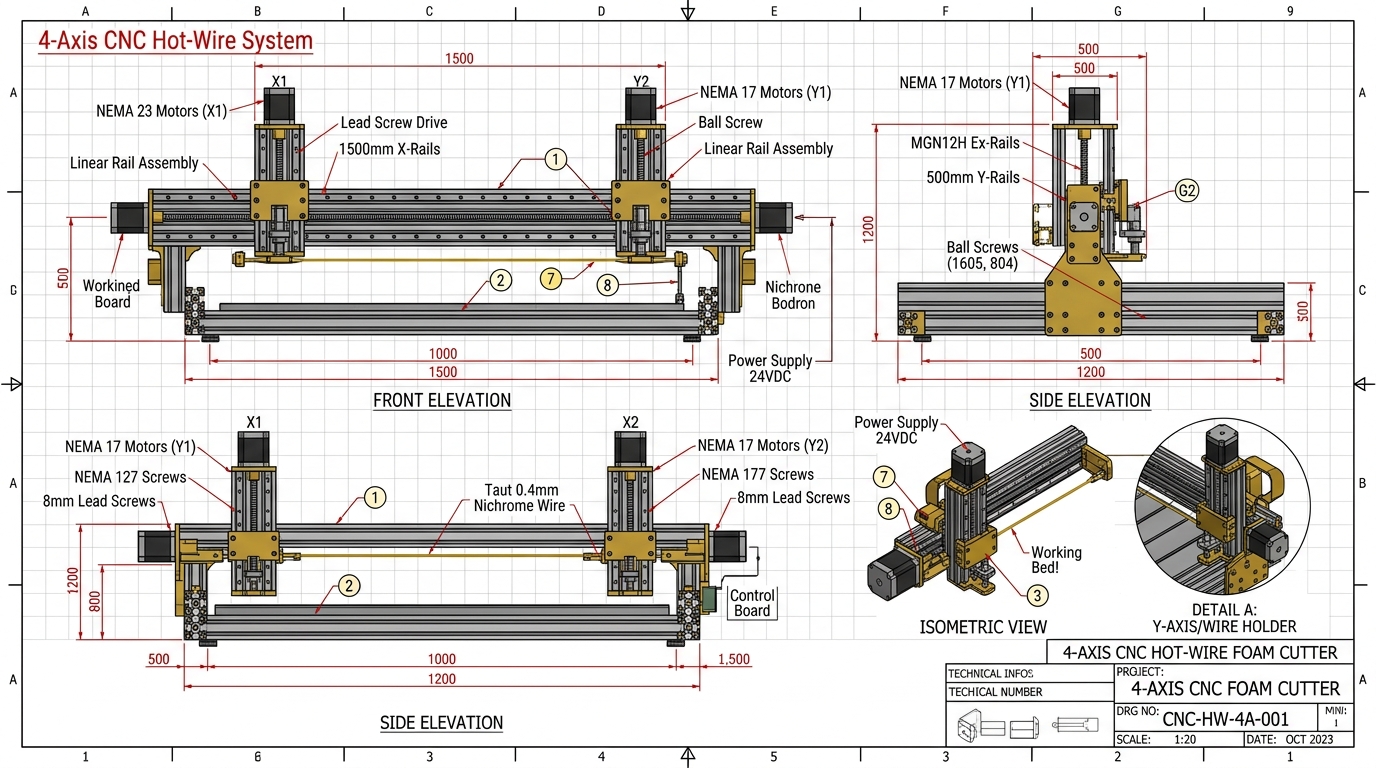
Designed and constructed a 4-axis CNC hot-wire foam cutter with dual synchronized gantry towers and a high-tension nichrome wire. The microcontroller-based GRBL firmware coordinates dynamic feed rates with PWM thermal calibration to fabricate high-precision aerospace airfoils and complex tapered sweep geometries.
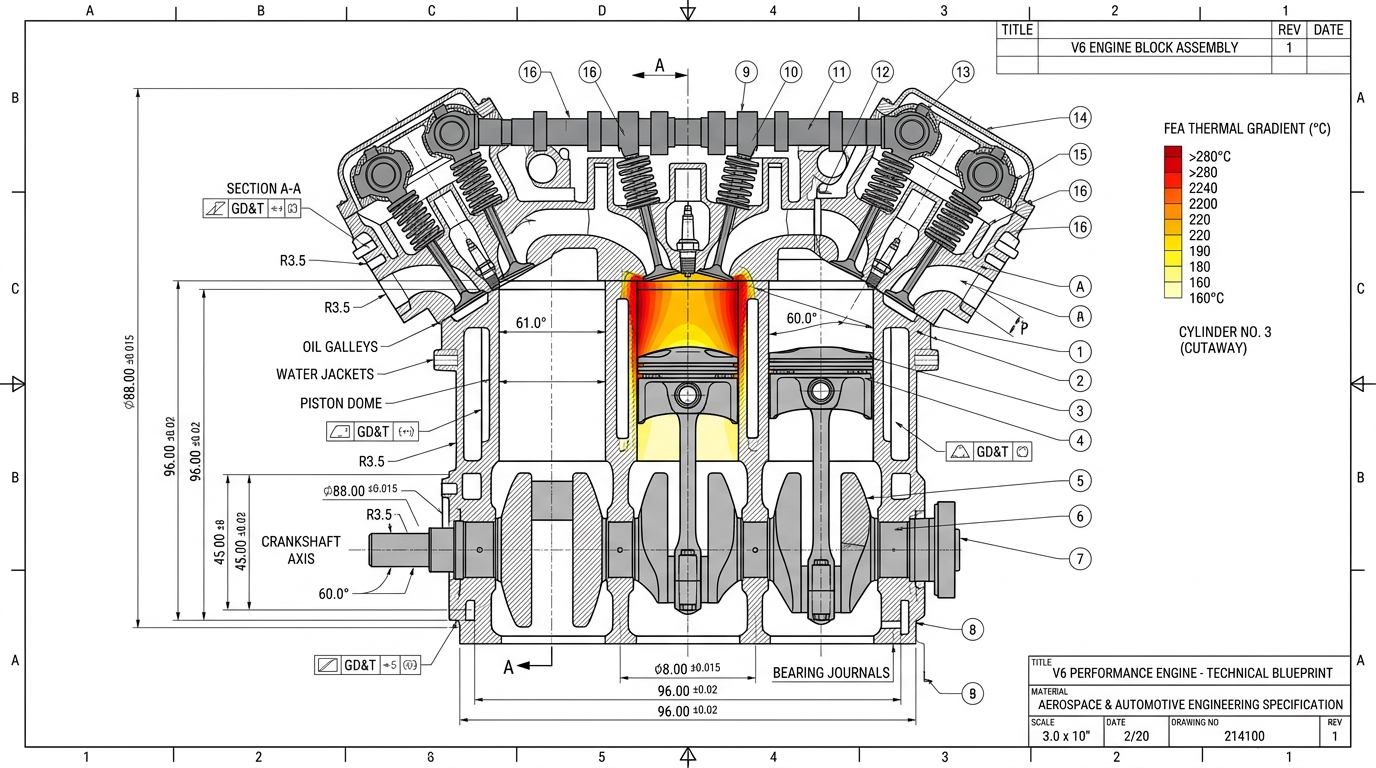
Conducted finite element thermal gradient analysis and fluid dynamics simulations of a V6 engine block to model combustion efficiency under dynamic thermal cycles. Resolved transient heat flux concentrations at cylinder boundaries during rapid velocity variations. Validated simulation accuracy against physical dyno metrics, yielding less than 4.1% deviation under peak power.
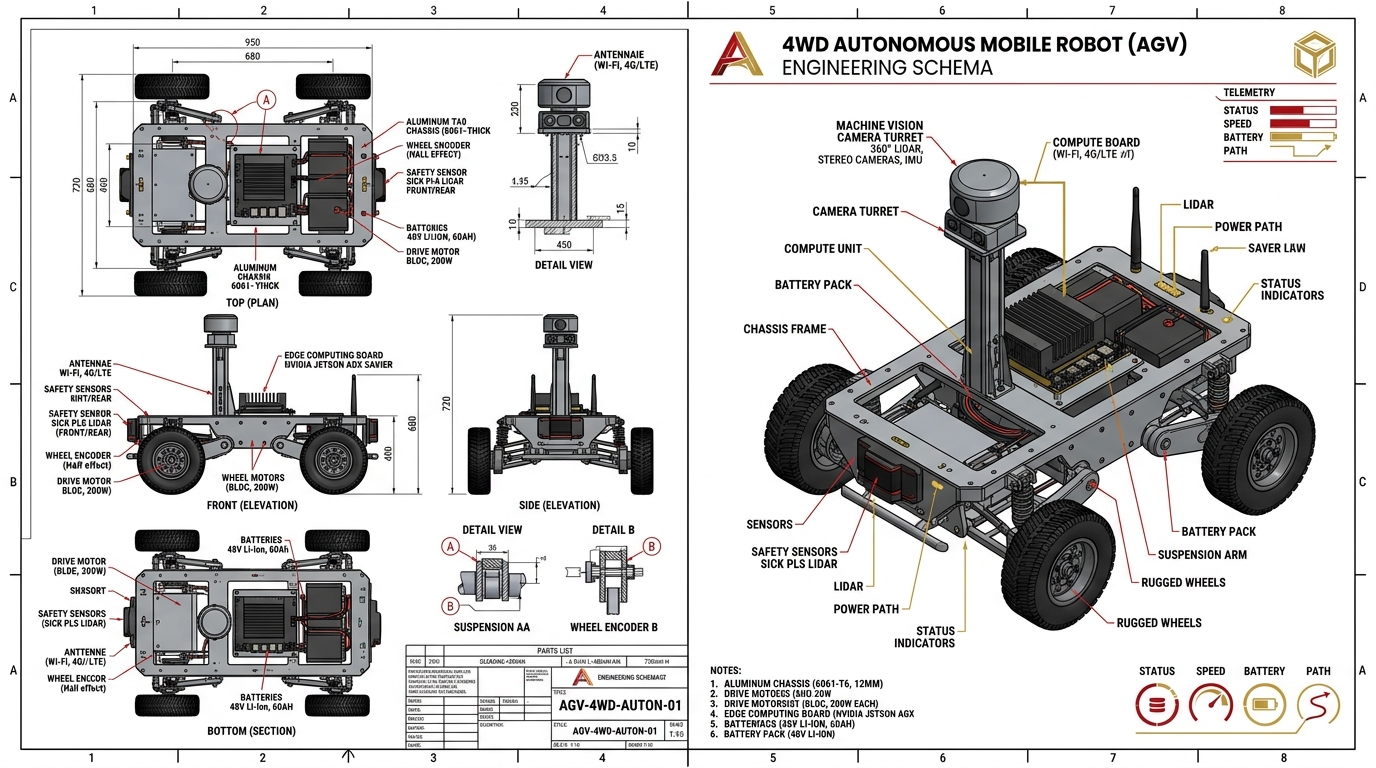
Engineered an autonomous mobile robot vehicle driven by an edge vision camera sensor pipeline running real-time Hough Transform line tracking and obstacle avoidance. Minimized image processing latency to stabilize PID navigation control at high speeds, demonstrating dynamic path-planning accuracy under 12mm across 200 Hz control loops.
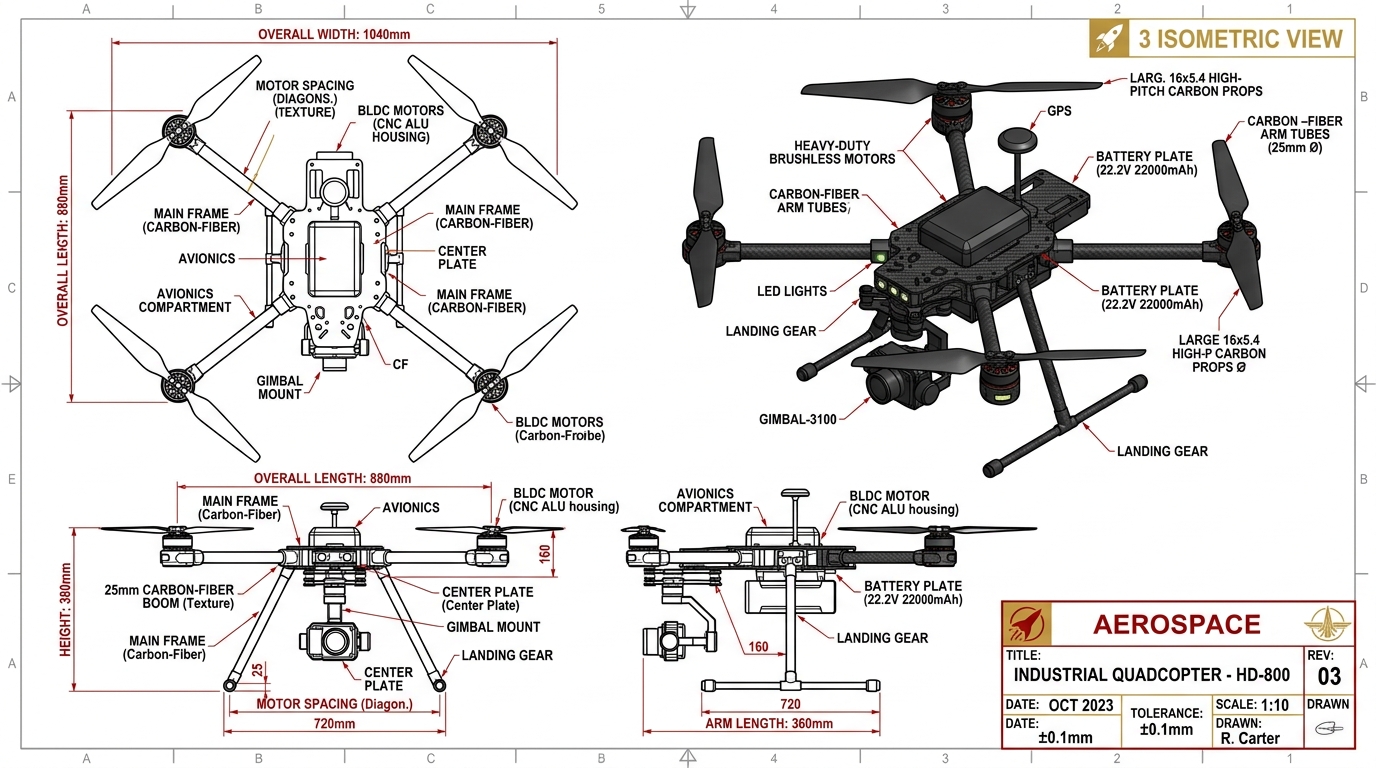
Designed and analyzed a carbon-fiber heavy-lift quadcopter platform using ANSYS structural and CFD downwash simulations to optimize thrust efficiency and structural arm stiffness. Validated composite frame fatigue thresholds under dynamic payload tests, achieving a 2.4 safety factor under a 12 kg operational payload.